AI Grand Prix
One hour, one LiDAR, one very aggressive racing line.
All workRepo under wraps
- When
- August 2026
- Where
- OpenAI × Formula Trinity AI Grand Prix
- Team
- Individual entry
- My role
- Built and tuned the driver
- Built with
- PythonLiDARControl logicSimulator
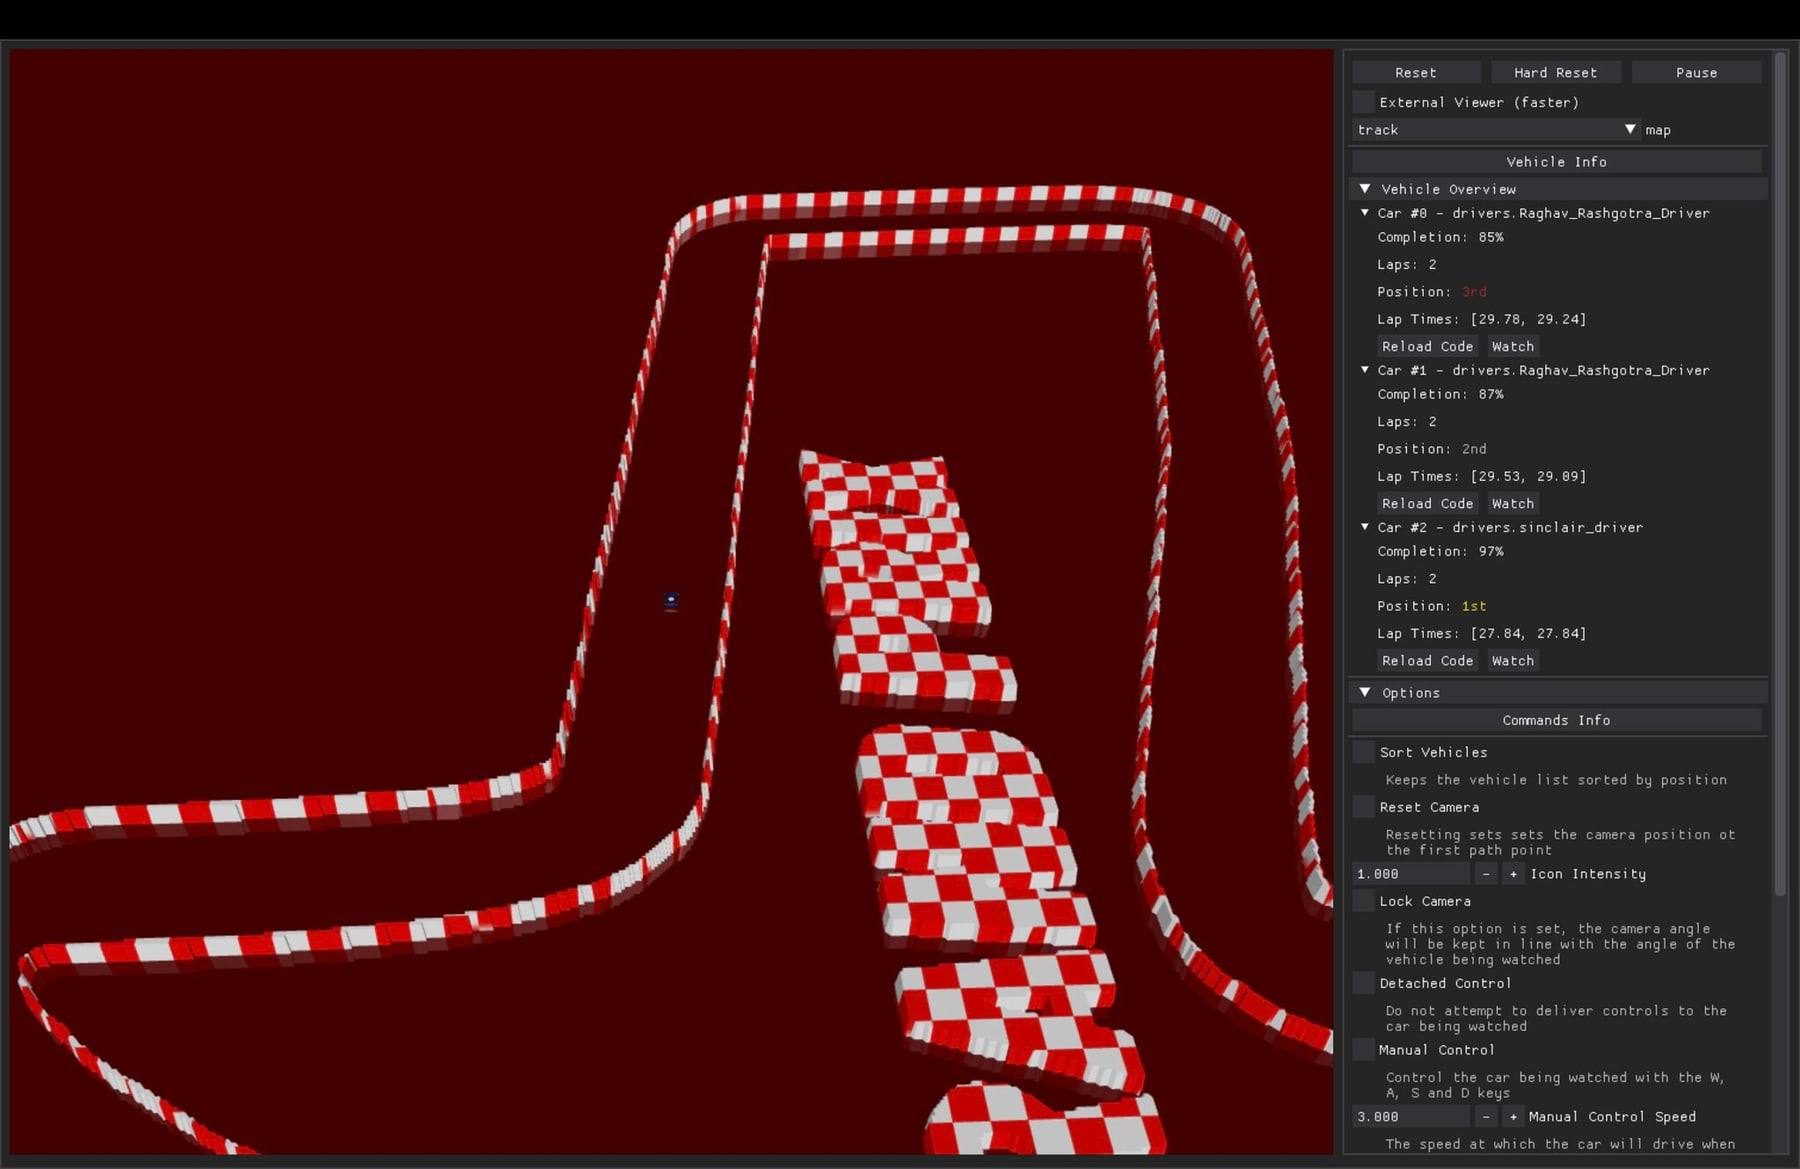
A Python LiDAR controller for an autonomous car in a custom simulator, built and tuned in about an hour. Best practice lap: 27.84 seconds.
01Chapter
The problem
Use LiDAR readings to choose steering and speed, fast enough to matter, in about an hour.
02Chapter
What I did
- Wrote an aggressive, wall-assisted racing-line controller in Python and tuned it to a 27.84-second best practice lap.
- Then, moments before the deadline, submitted the experimental version instead of the stable one.
03Chapter
Afterwards
The lesson stuck: protect the known-good build. I have since been reading into reinforcement-learning approaches.
Private repository
The code lives in a private repository. If you’d like a walkthrough, get in touch.